True mobility
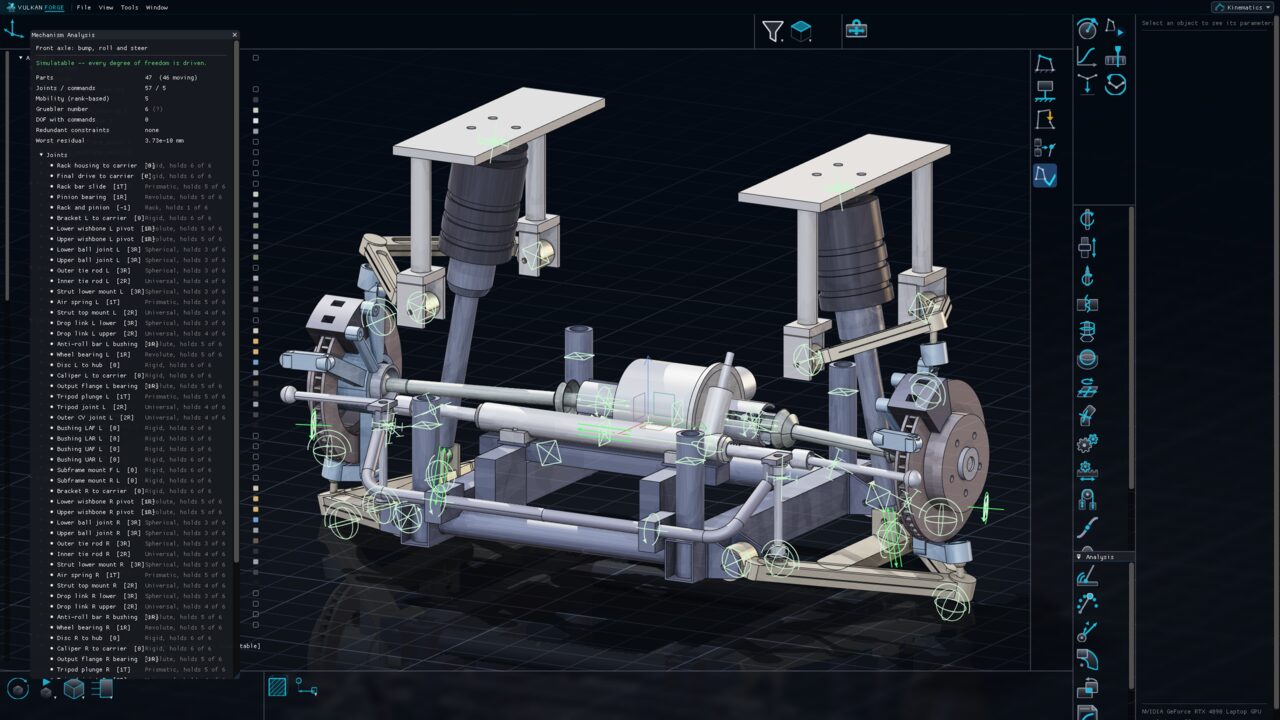
Degrees of freedom come from the rank of the constraint Jacobian rather than a counting formula, so a redundantly but consistently constrained mechanism reports its real mobility; both numbers are shown when they disagree.

Kinematics
Turn an assembly into a mechanism: connect instances with joints, ground one part, drive the remaining freedoms with commands or laws of time, and simulate. Mobility, speeds and accelerations come from the constraint Jacobian, and reports, sweeps and clash-in-motion turn the motion into numbers.
Why it matters
Degrees of freedom come from the rank of the constraint Jacobian rather than a counting formula, so a redundantly but consistently constrained mechanism reports its real mobility; both numbers are shown when they disagree.
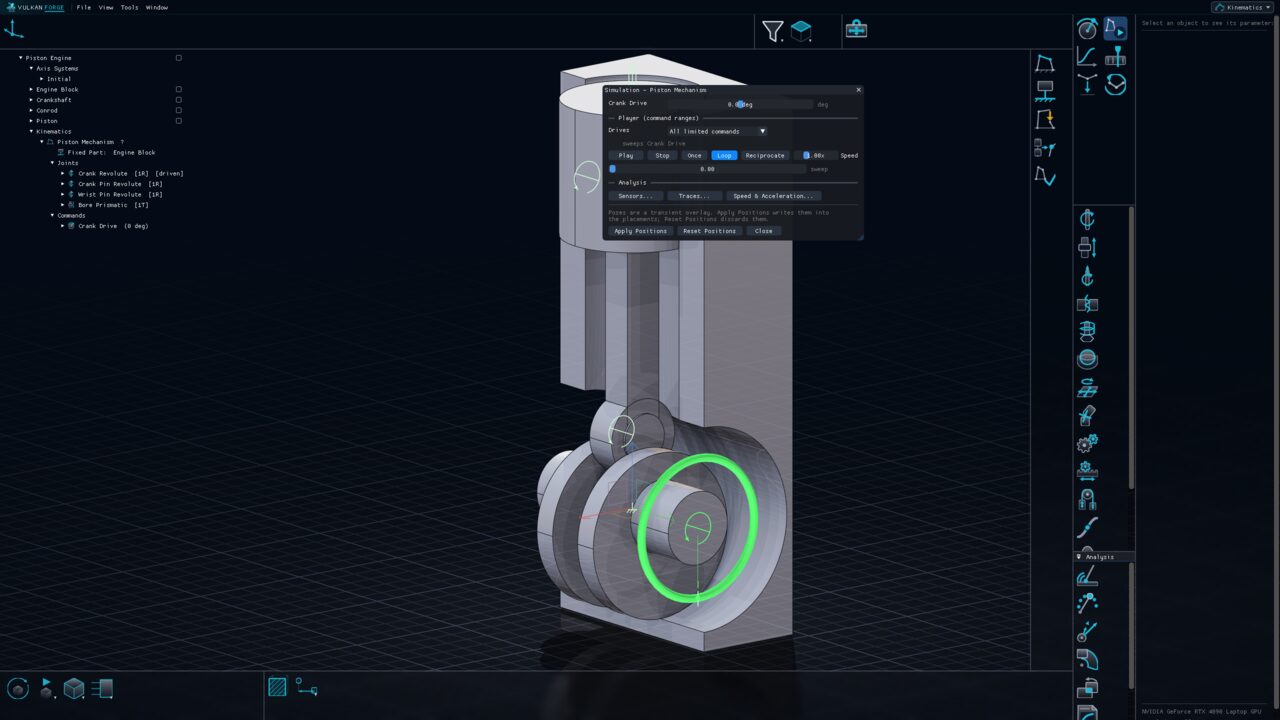
Speeds and accelerations are derived from the same Jacobian as the position solve — on a piston at top dead centre the value matches the closed form to 2.4e-13, where differencing poses is off by 3.7e-4.
Beyond revolute, prismatic, cylindrical, spherical, planar, screw and universal joints: gear, rack and cable couplings, plus point-on-curve, slide-curve and point-on-surface pairs for cams.
A compiled replay carries the signature of the mechanism it answered; when the mechanism changes it is reported stale and refused, never silently replayed.
The Report tracks points, axis systems and measures through a sweep; the charts are built in the backend, so the viewer, the PDF and the CSV cannot drift apart.
Operations
The complete inventory, toolbox by toolbox, with the icons exactly as they appear in the application.
 New Mechanism
 Fixed PartPick the instance that is ground
 Mechanism AnalysisDOF with and without commands, redundancy, "can be simulated" verdict
 Heal MechanismProposes the values that restore consistency, applied only on Apply
 Convert ConstraintsProposes the joints the assembly constraints imply; nothing made until OK
 Revolute
 Prismatic
 Cylindrical
 Rigid
 Spherical
 Planar
 ScrewShared axis plus pitch and hand; one coupled freedom
 Universal
 GearCouples two joints by a signed ratio snapped to an exact fraction
 RackCouples a rotation and a translation in mm per turn
 CableCouples two translations by a reeving ratio
 Point On CurveA point riding an exact curve; contact lost at an end is reported
 Slide CurveTwo curves kept tangent — how a flat-face cam follower is modelled
 Point On SurfaceA point riding an exact surface
 Which Joint Do I Need?Gallery of joint types, narrowed to what the picked pair can make
 CommandDrive a joint freedom with value/min/max parameters
 SimulateSliders plus a player: once, loop or reciprocate
 Law of TimeDrive a command by a formula of time, with a live plot
 ReplayCompile a scrubbable run; refused when the mechanism has changed
 Apply PositionsWrite the current pose into the instances' placements
 Reset PositionsDiscard the pose overlay
 SensorA measured quantity over a run; CSV export
 TraceA point's path with its sampling error stated; convert to a spline
 Speed & AccelerationEvery joint's analytic rate and acceleration at the current pose
 Swept VolumeVolume swept by moving parts, with a published safety margin
 Motion StudyClash and minimum clearance over the motion
 Dress-UpColour by role; show, ghost or hide non-participating parts
 ReportCharts and coloured paths over a sweep; viewer, PDF and CSV
In use
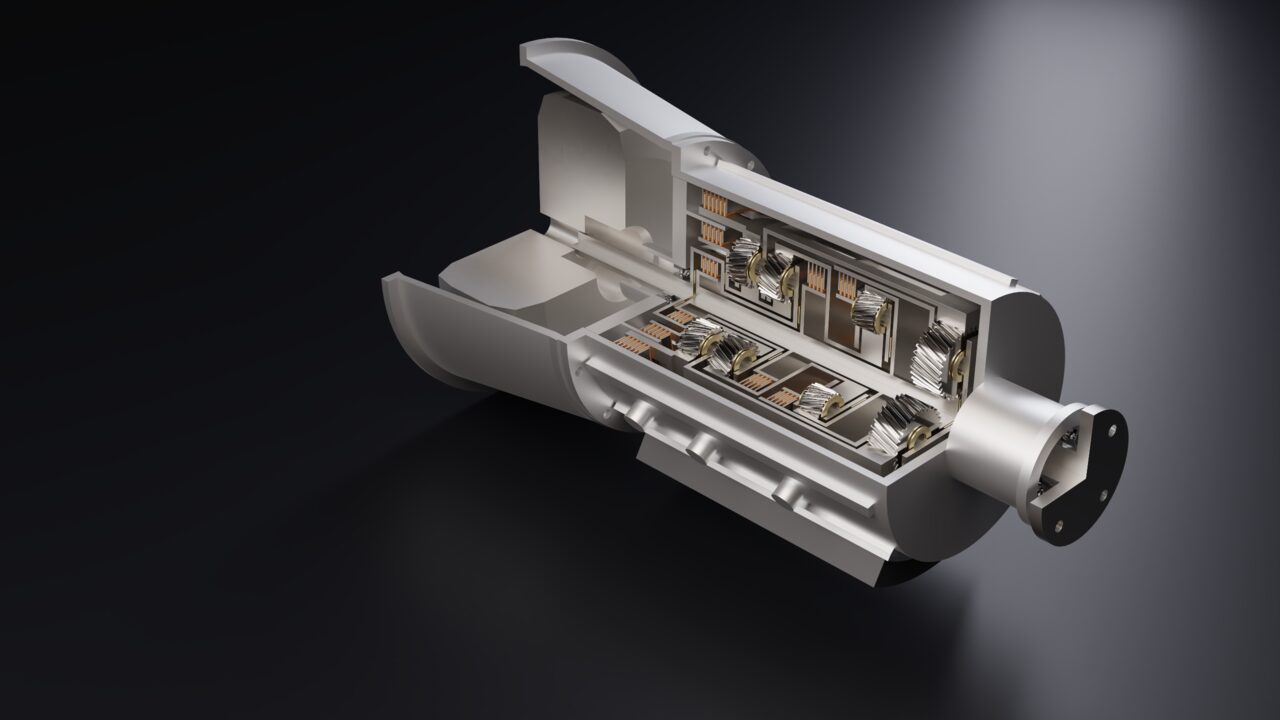
Transmission
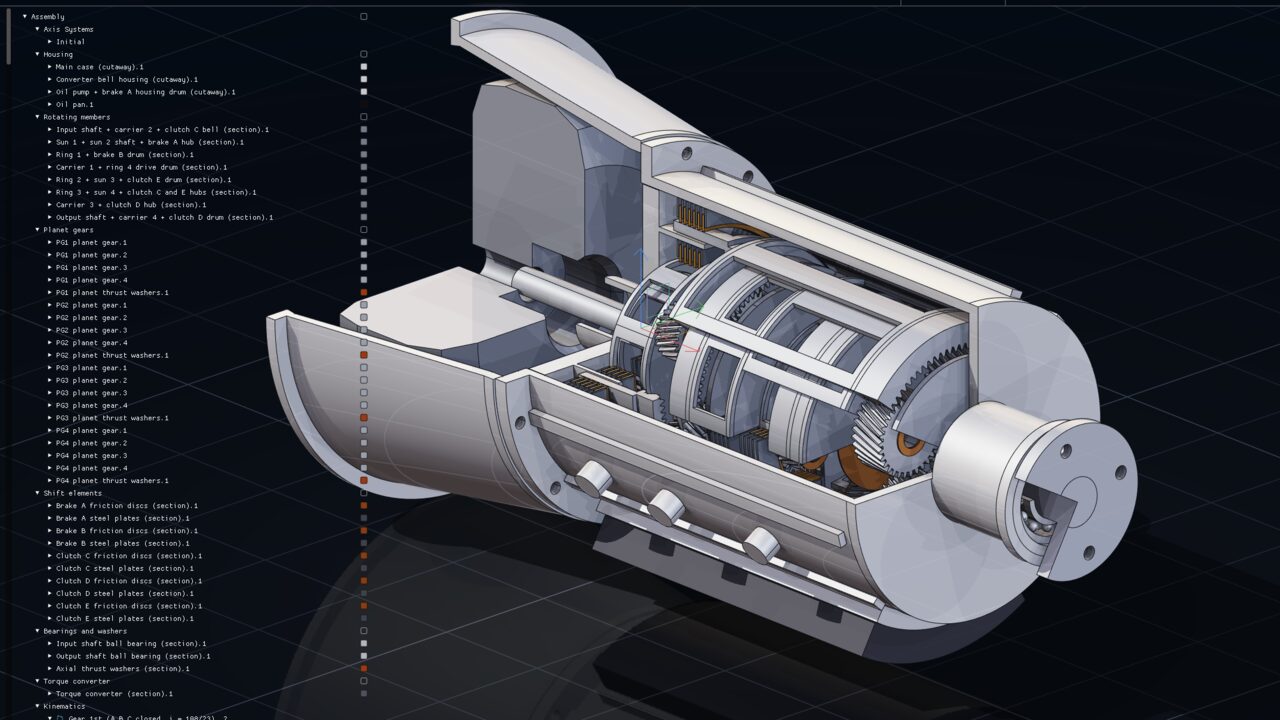
A cutaway 8-speed automatic transmission with four helical planetary sets and five shift elements, every tooth an exact involute. It reproduces all nine published gear ratios and runs a 3rd-to-4th shift as a mechanism.


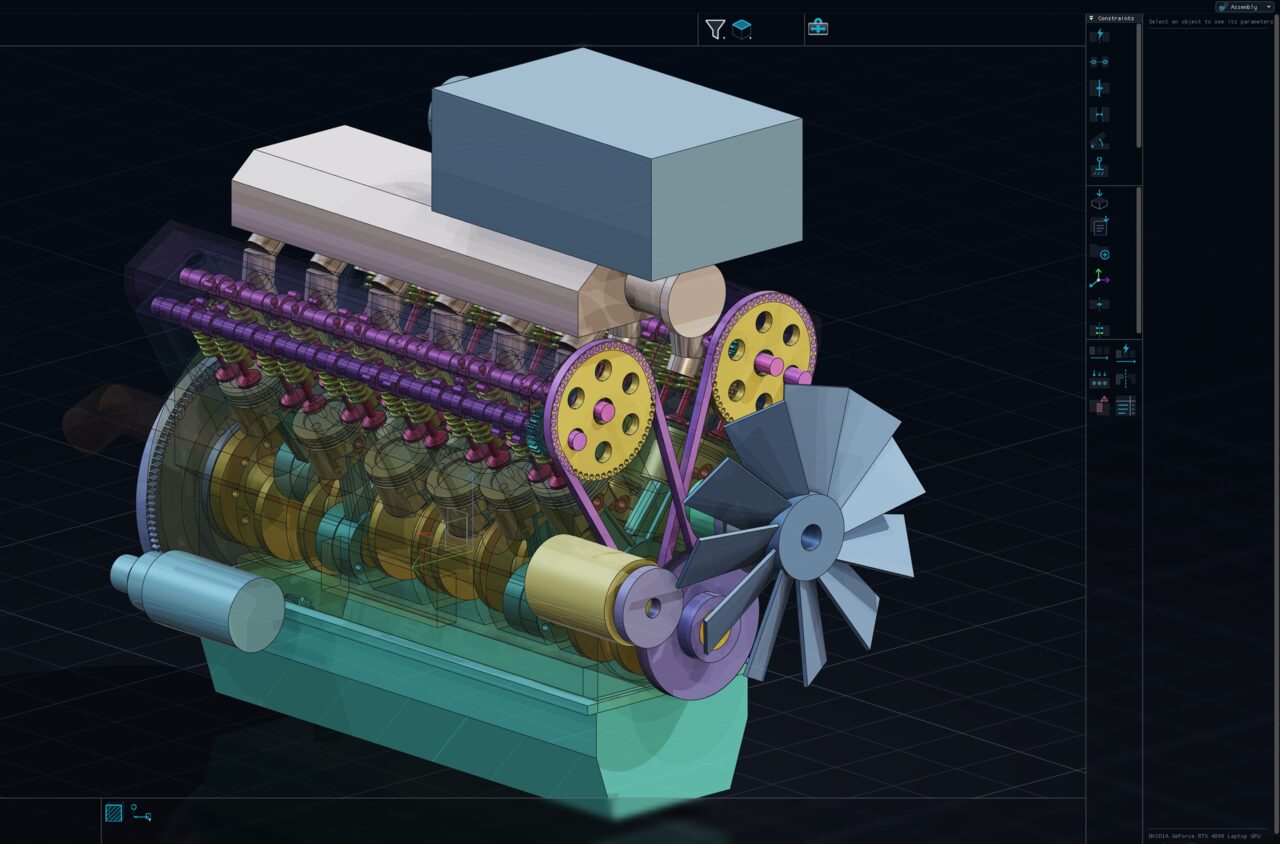
Engine
A complete 60° V12 with crank train, four camshafts, 48 valves and its accessories. One crank angle poses the whole engine.
Chassis
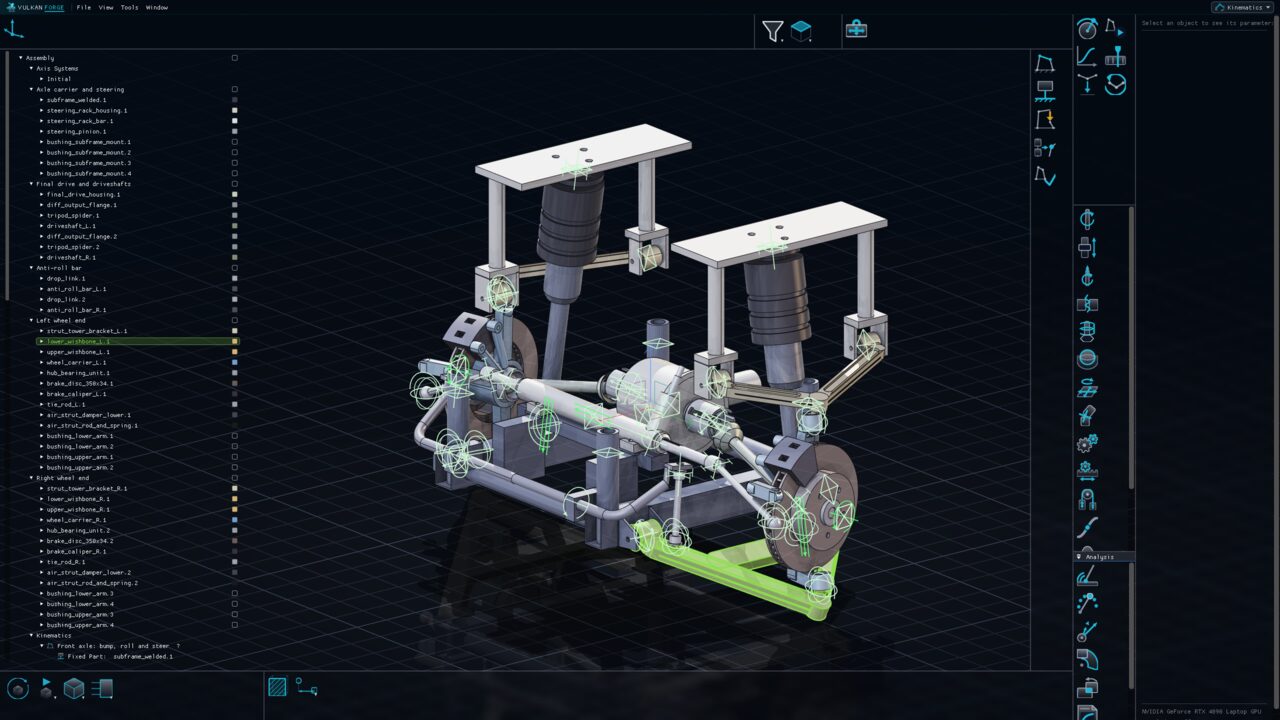
A complete double-wishbone front axle with steering and driveline, measured over its whole travel and steering range — then rebuilt with bushing stiffnesses and tyre loads for a full kinematics-and-compliance study.